 Impulse Modena RacingWorkNov 2023 – Jun 2024
Whole Motorcycle Dynamic Model and Validation
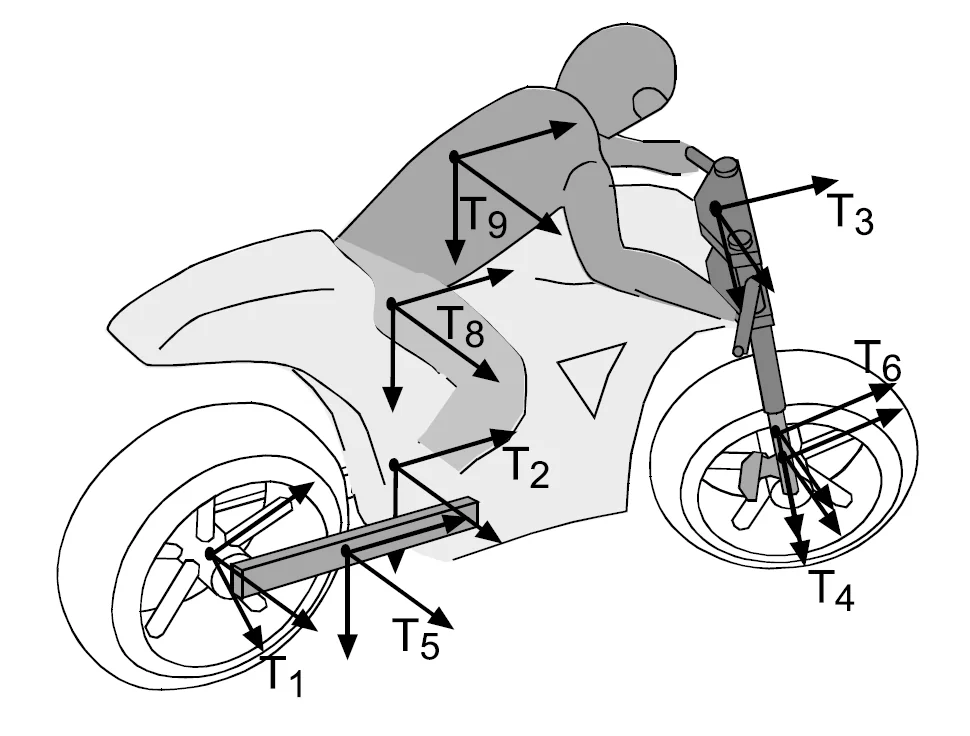
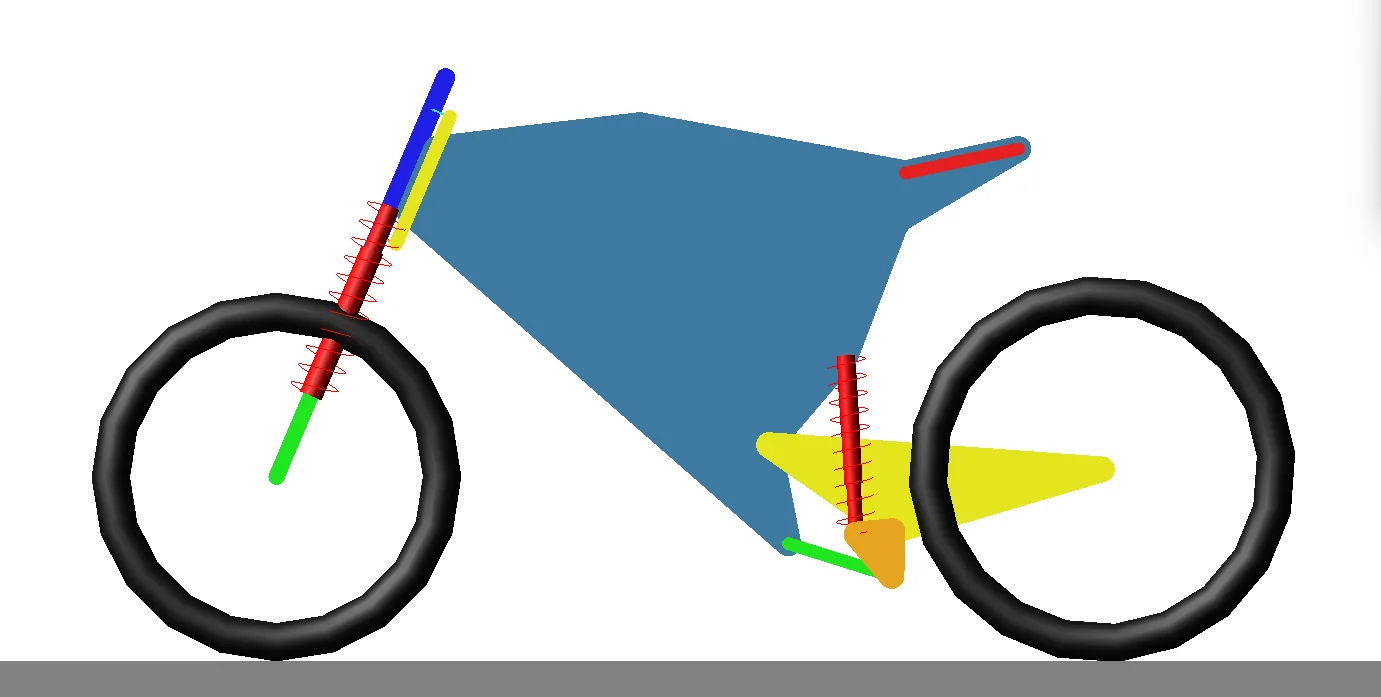
Rebuilt an undocumented VI-grade motorcycle model: mass and inertia recalculated from the CAD, test manoeuvres in VI-grade and validation against track telemetry, until it became the team’s reference for setup decisions.
A model nobody could explain
At the start of the MotoStudent cycle, the Vehicle Dynamics division inherited a VI-grade model of the bike. Its authors had left the team: no documentation, no reasons behind the parameters, no validation. Before using it for setup decisions, every number had to be checked again.
Back to the CAD, then out on track
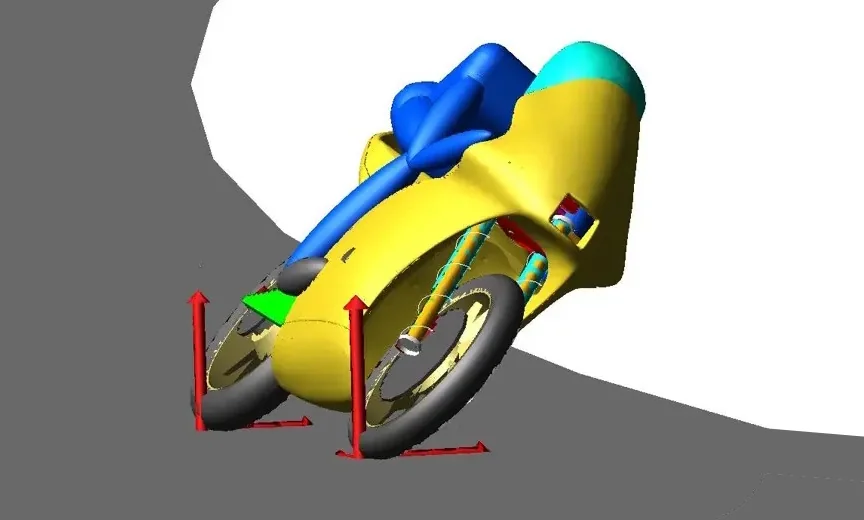
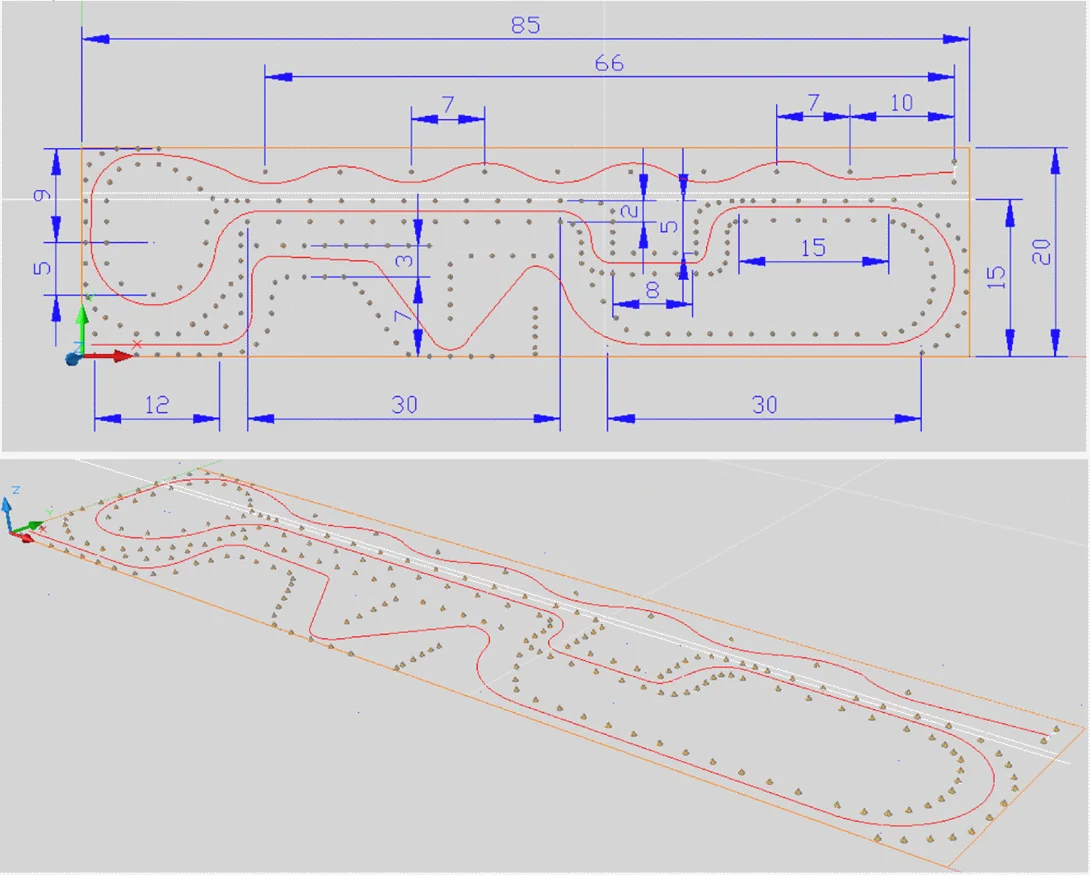
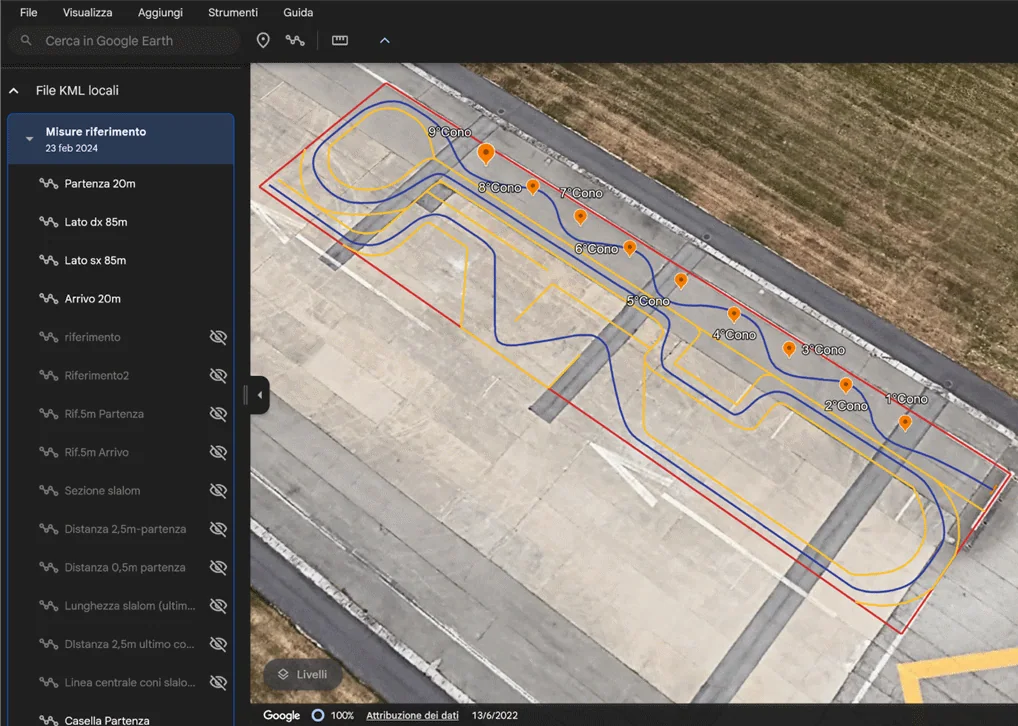
With a colleague I recalculated mass and inertia of every sub-assembly from the CAD, adding small variations to see how sensitive the model was. We worked in VI-BikeRealTime for the model, VI-Road for the test track and VI-EventBuilder for the basic manoeuvres: acceleration, braking and slalom.
Tires and track stayed as inherited for the moment, so that the two of us could focus on the core dynamics. Once the bike was running, I processed the track telemetry and compared it with the simulation.
A model the team could finally trust
Simulated lap times moved close to the measured ones, and the gap kept shrinking season after season. The model became the reference for setup choices and performance estimates before any physical test, and the base for the following year’s work.
Book a call: the calendar opens right here.
Book a call
Pick a day and time for a Google Meet video call
Choose a day
No free times on this day.
Booked!